Arduino Radar System
A hardware project that uses an Arduino microcontroller and ultrasonic sensors to emit sound waves, map object distances via time-of-flight, and visualize the data in real-time.
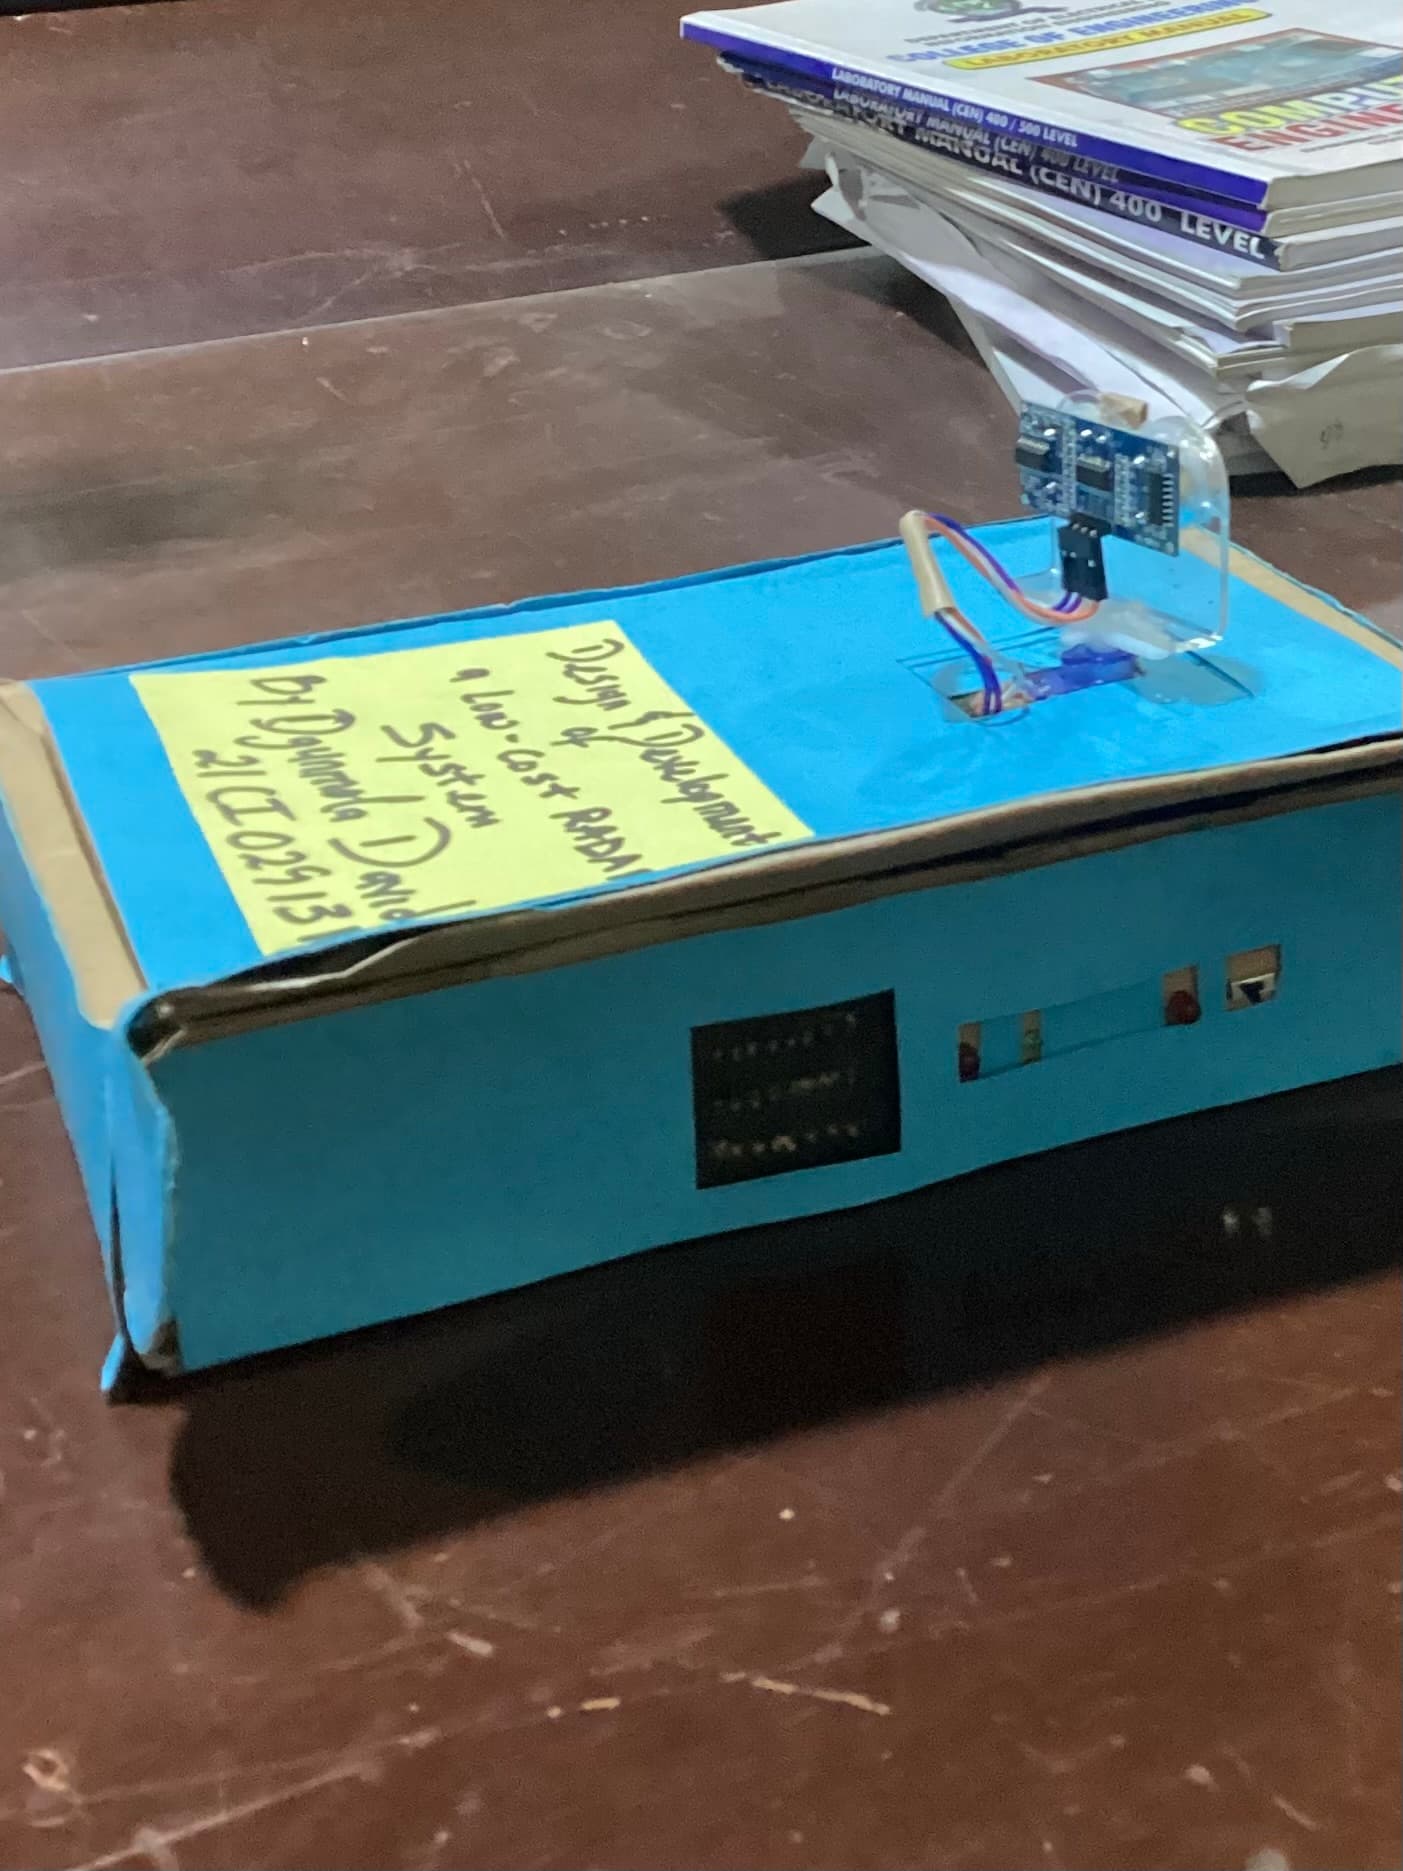
Hardware Engineering & Real-Time Visualization
Designed and developed a low-cost, functional mini radar system to explore the integration of hardware sensors with real-time software visualization.
System Architecture
The project combines physical computing with graphical processing:
- Sensing Engine: Utilizes ultrasonic sensors to emit high-frequency sound waves. The system measures the echo return intervals and applies the "time-of-flight" principle to calculate precise object distances.
- Actuation: Driven by a servo motor programmed to sweep the sensor continuously across a 180-degree radius, establishing a broad field of detection.
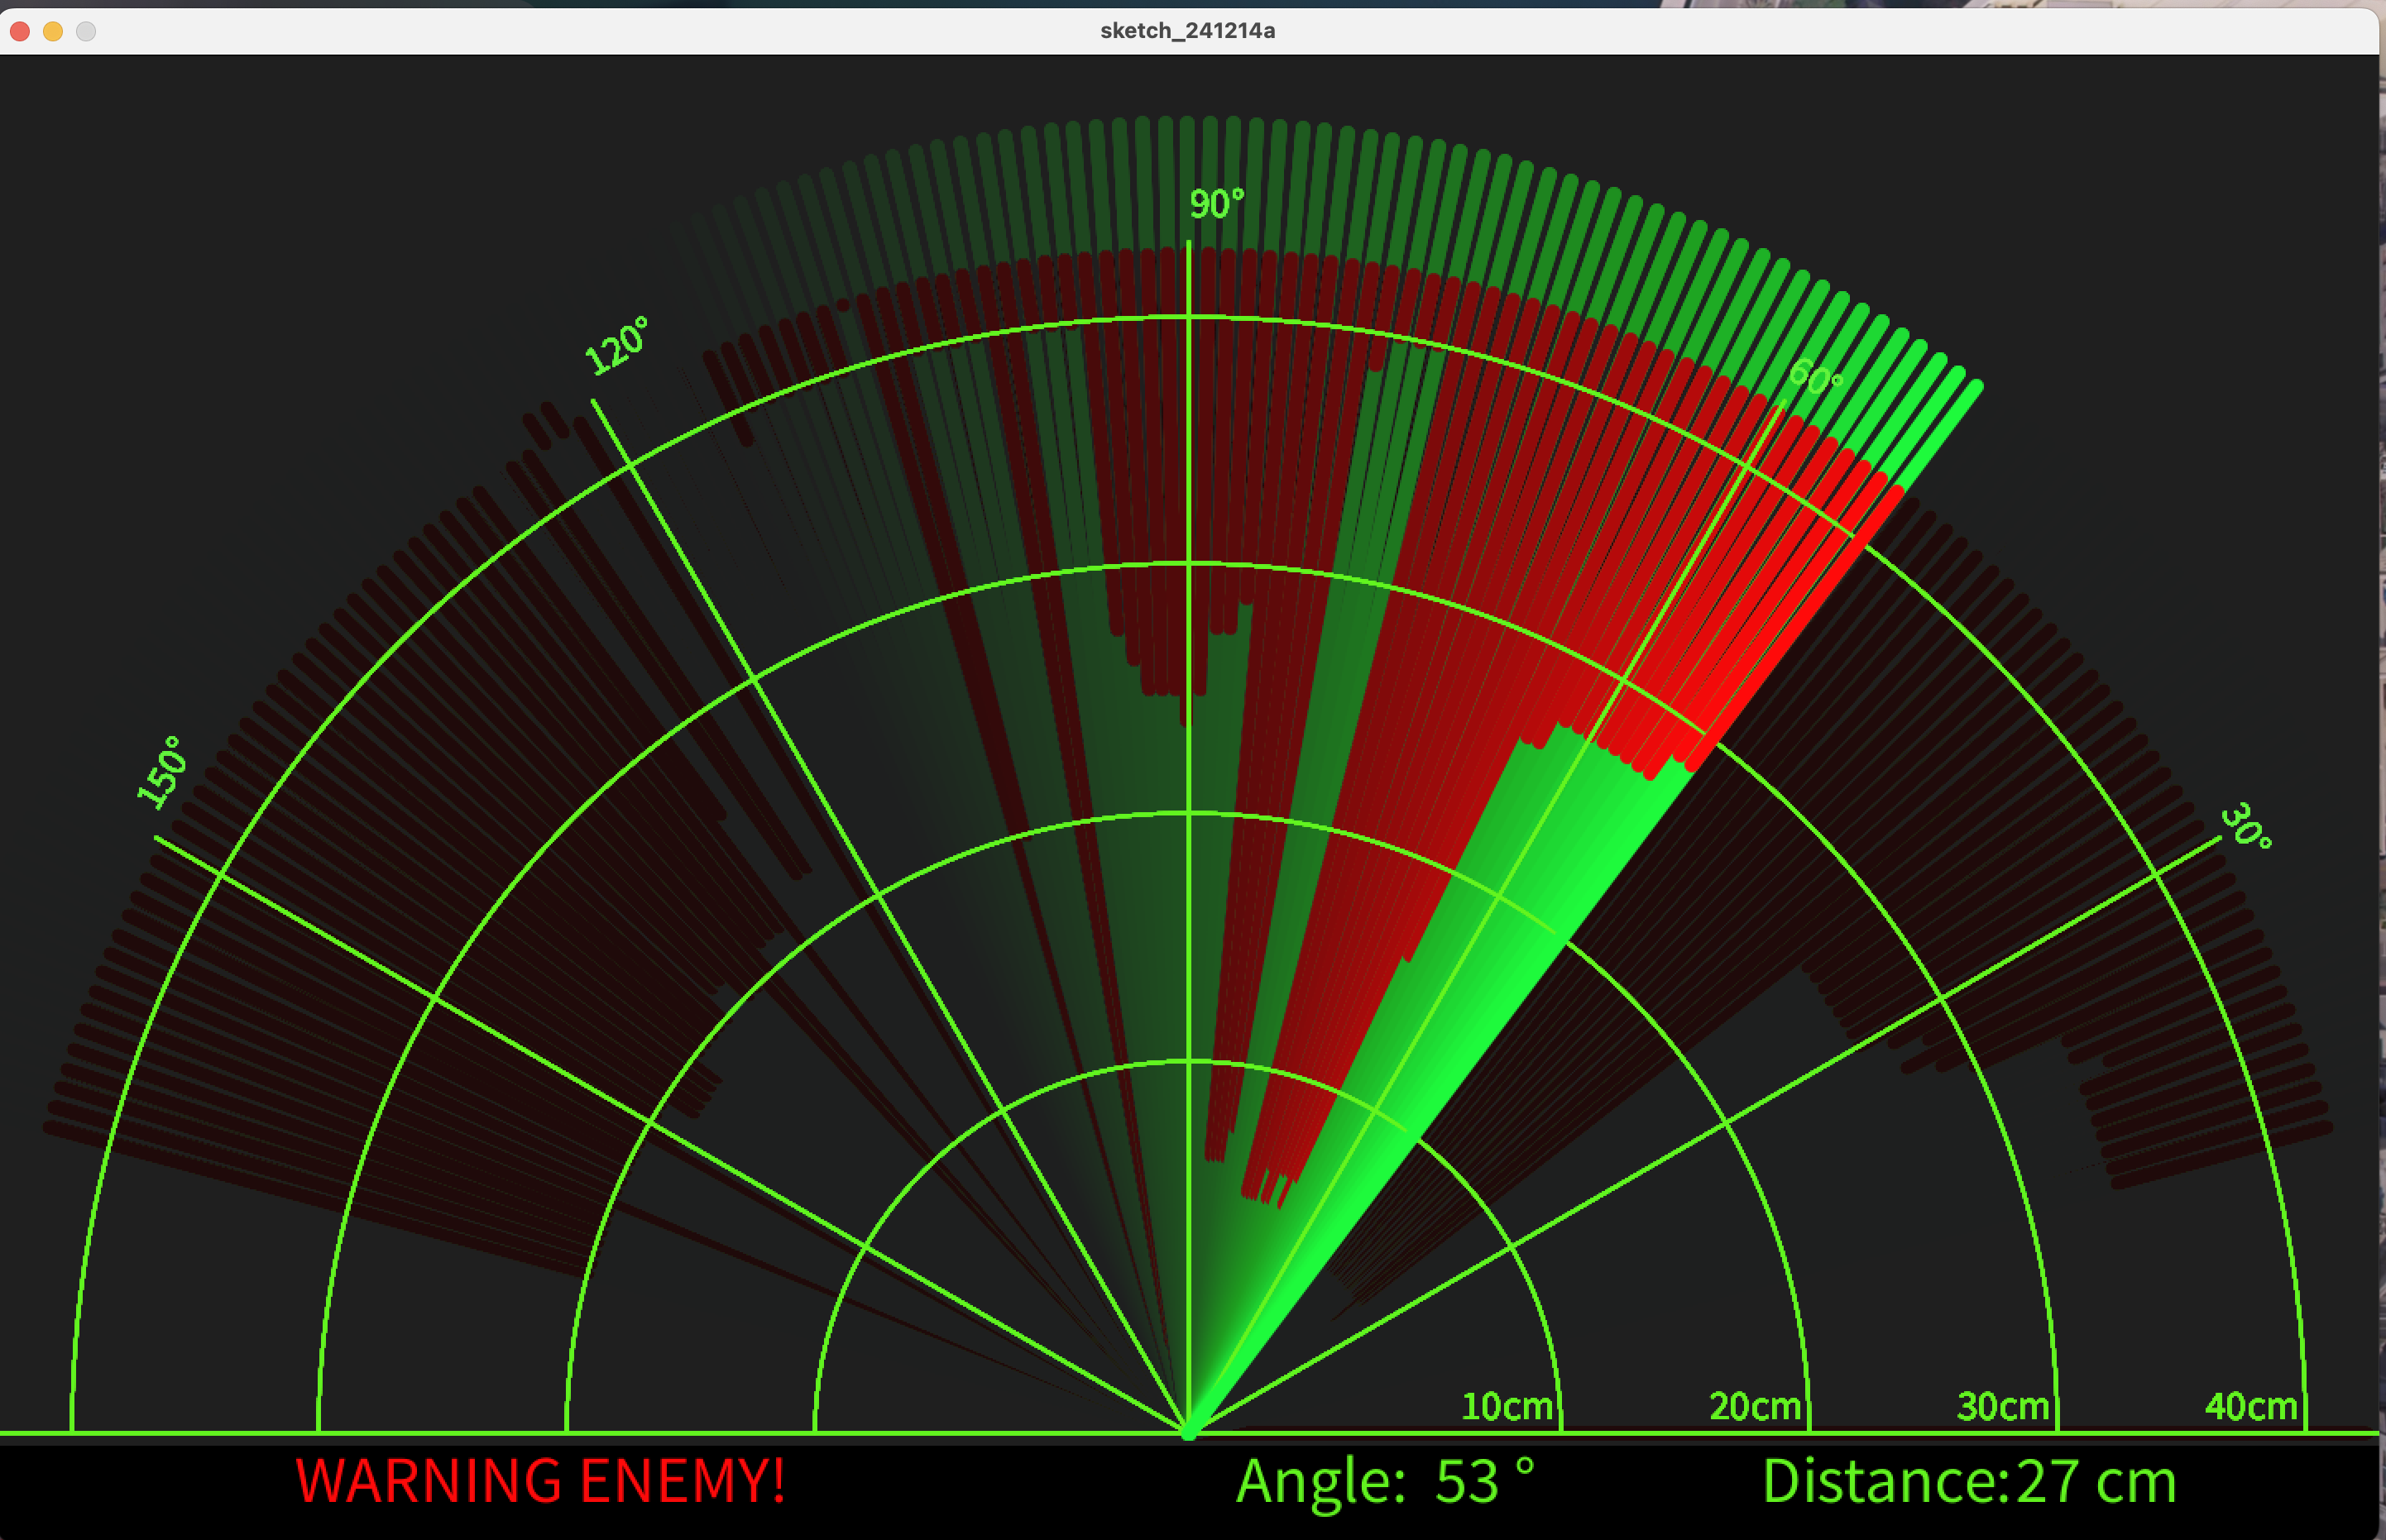
- Data Visualization: Built a real-time graphical user interface (GUI) using Processing. As the Arduino streams serialized spatial data over serial communication, the GUI plots the detection vectors, simulating a traditional radar screen.
Components
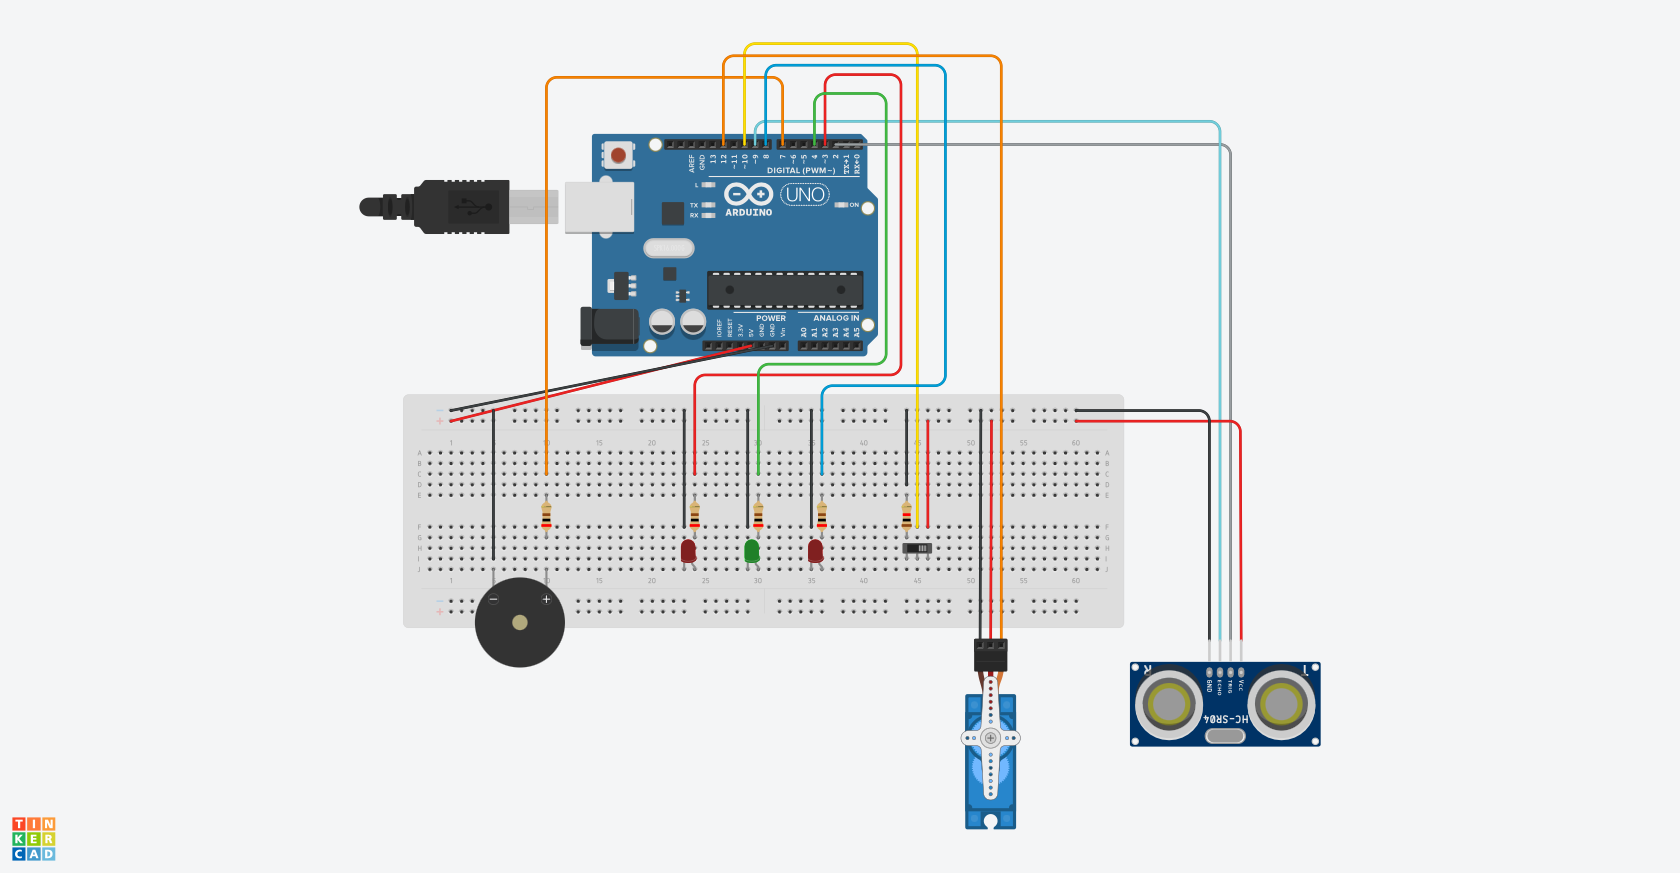
| Component | Quantity |
|---|---|
| HC-SR04 ultrasonic sensor | 1 |
| Arduino Uno | 1 |
| 9 g servo motor | 1 |
| Active buzzer | 1 |
| 220 Ω resistors | 4 |
| 1 kΩ, 2 W resistor | 1 |
| Slide switch | 1 |
Technical Challenges Overcome
The primary challenges lay in the hardware-software handshake. Early iterations suffered from sensor jitter and serial communication bottlenecks. I resolved these issues by refining the C++ polling frequencies and implementing strict calibration routines to ensure the sweeping mechanism remained perfectly synchronized with the GUI rendering.
The project successfully demonstrates an accessible approach to developing spatial awareness modules for small-to-medium scale robotics.
Future Improvements
Longer range and better accuracy, steadier readings through filtering and calibration, wireless remote monitoring, a more capable controller such as a Raspberry Pi, and a sturdier enclosure and power design.
Figures
Stack
- Arduino
- C++
- Processing
- Robotics
- Hardware